AIRLab multimodal sensing platforms
An in-house RGB, event, and polarization sensing rig on an industrial arm, and a quadruped robot that takes it into the field.
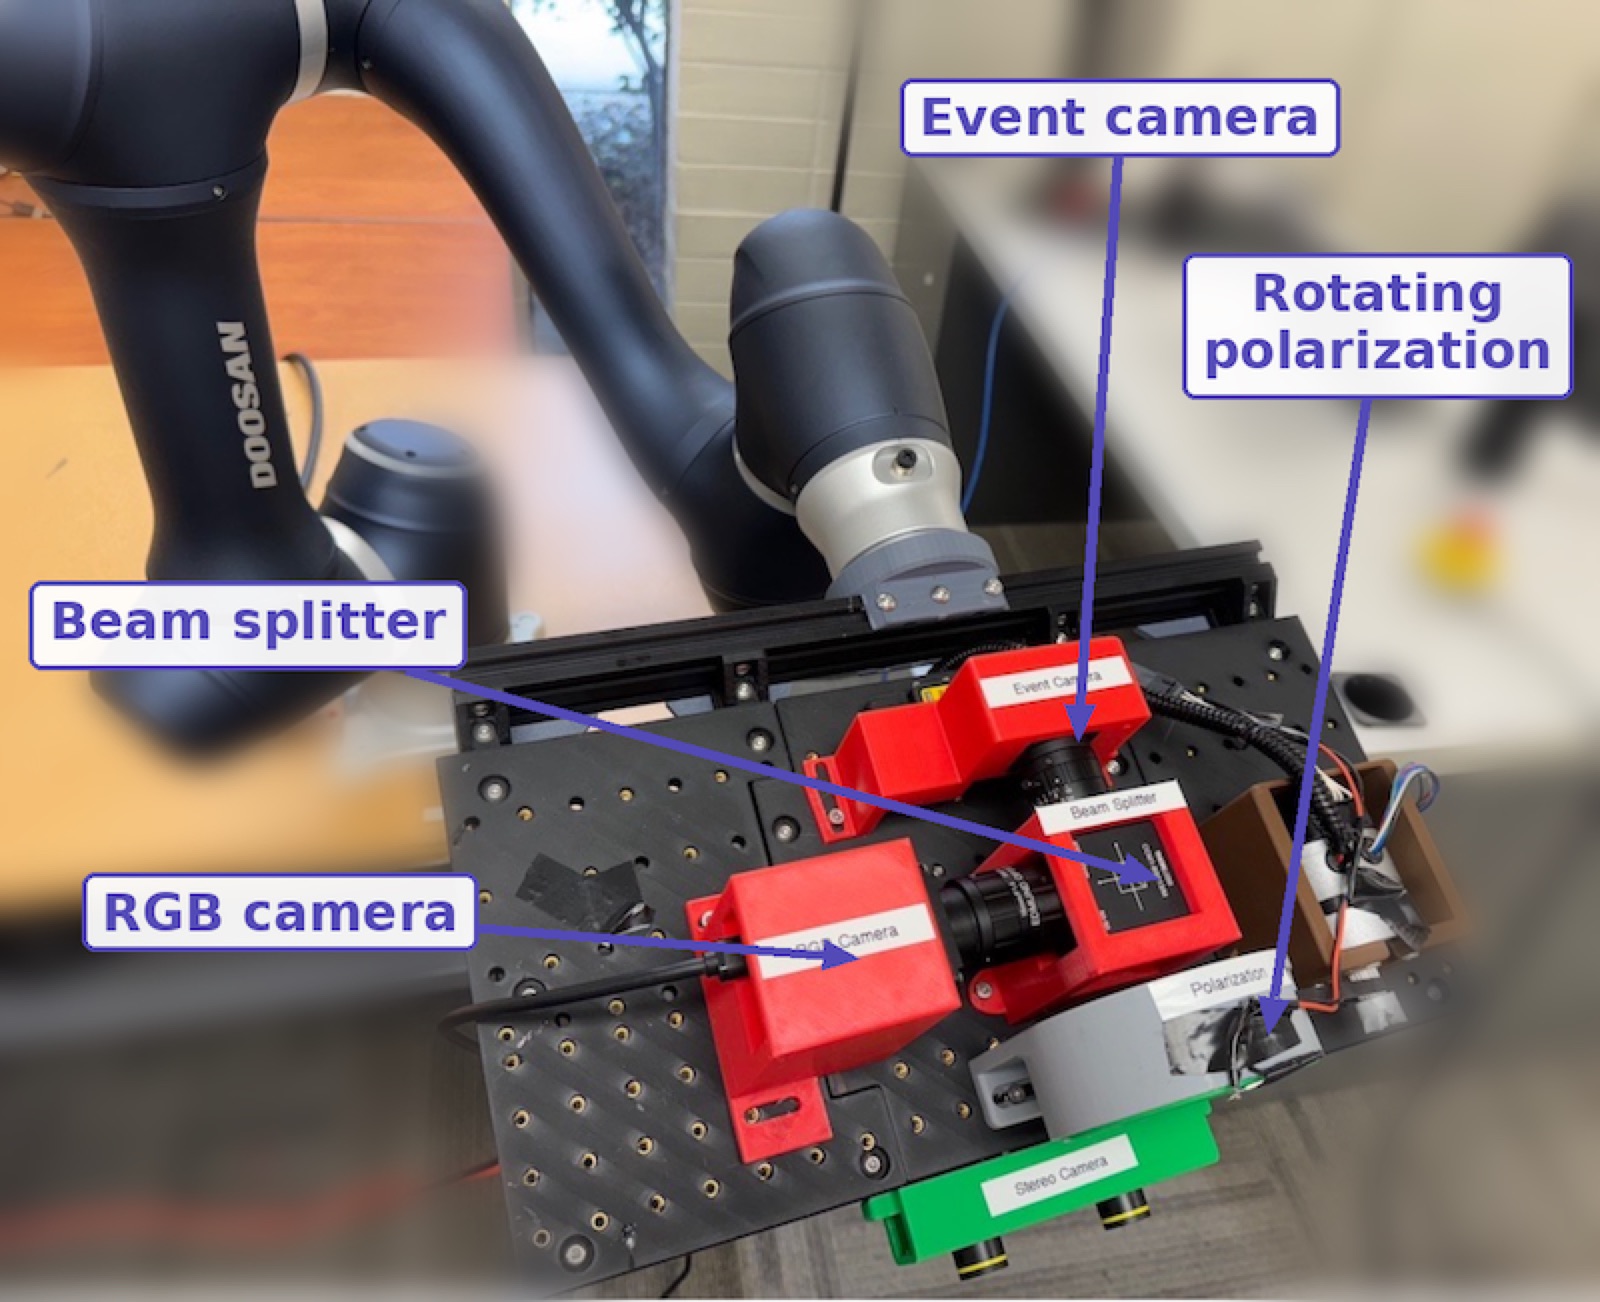
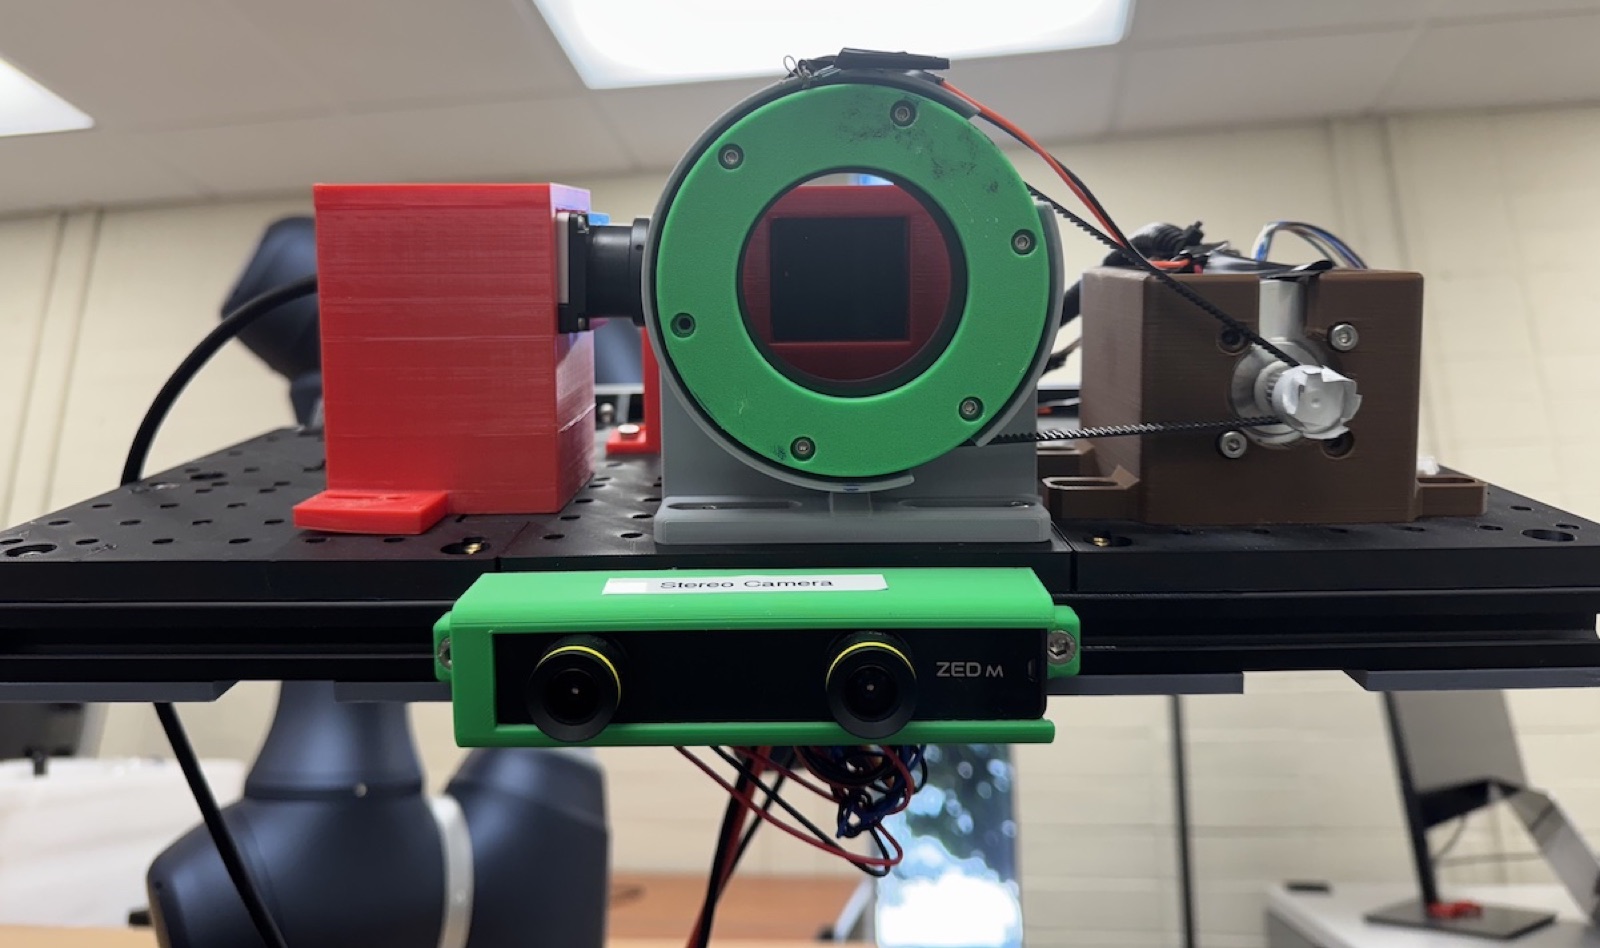
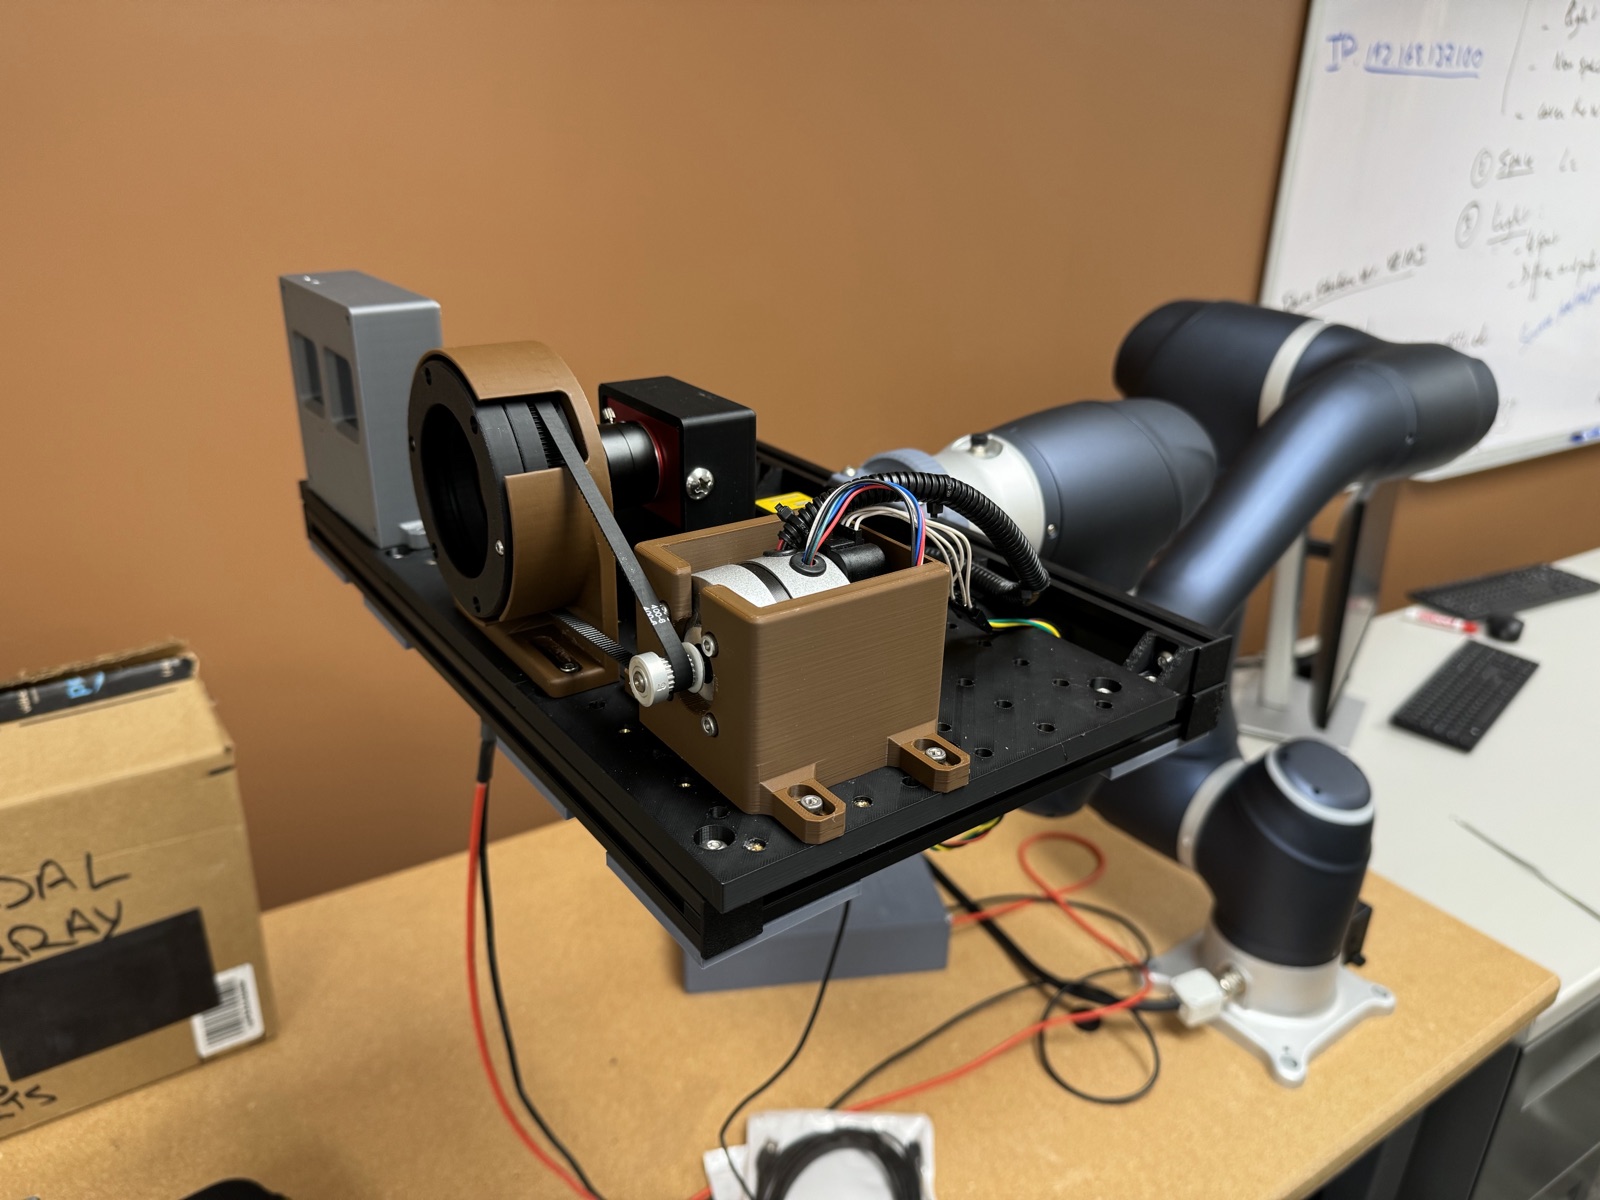
The experimental core of the lab is a multimodal sensing platform built in-house with student researchers. Its sensing module was designed and fabricated by Ahmed Mahmoud, an M.S. researcher in the lab. A beam splitter gives the RGB and event cameras a shared optical path, a rotating polarization module modulates the incoming light, and a stereo camera supplies depth. Mounted on a 6-DoF Doosan A0509 industrial arm, the platform supports repeatable sensor motion and controlled viewpoints for systematic study of how light–material interaction encodes geometry and material identity.
To take these experiments out of the lab, AIRLab operates a Unitree Go2 quadruped with an NVIDIA Jetson Orin onboard computer and LiDAR. Event sensing and a liquid-crystal polarization rotator, which switches the analyzer state electronically more than 1,000 times per second, are being integrated onto it for mobile perception, autonomous 3D mapping, and inspection in visually challenging environments.
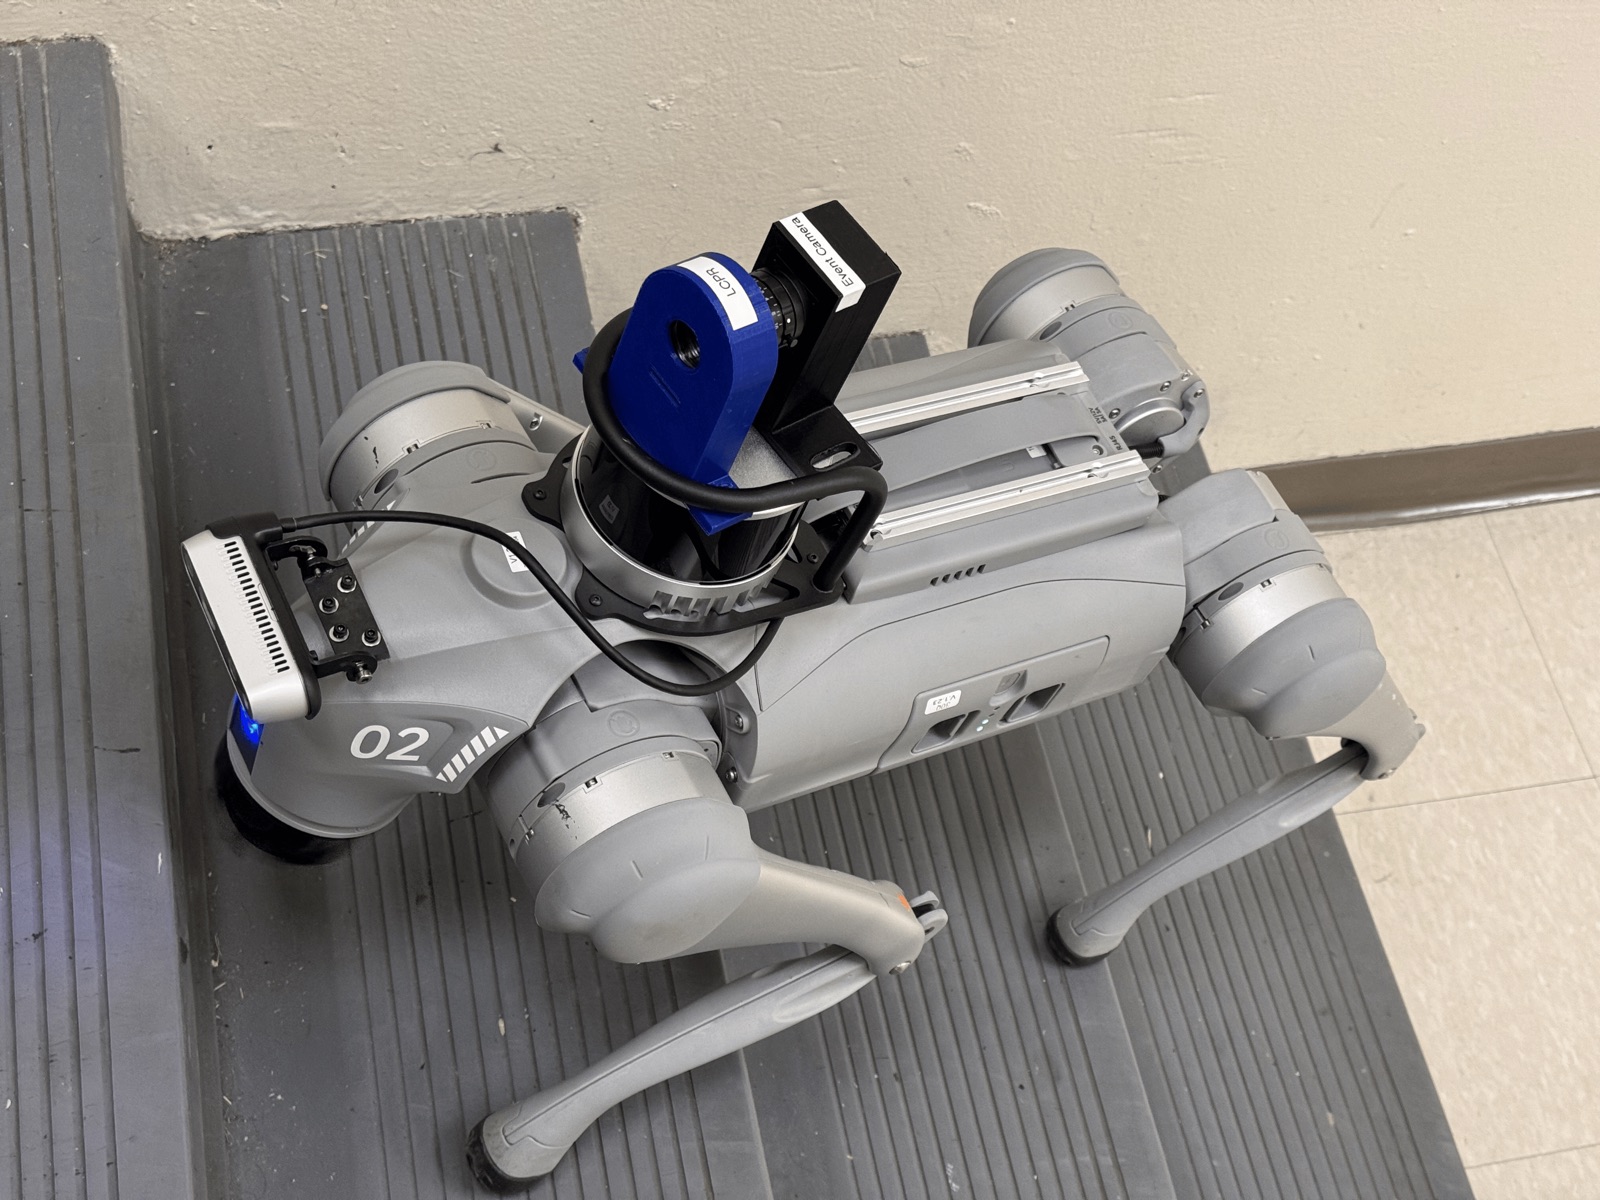
The next-generation polarization sensor replaces the mechanical rotation stage with a liquid-crystal polarization rotator: