EvSat3D — event-based satellite pose and 3D reconstruction
Recovering satellite pose and shape with an event camera under glare, saturation, and reflections that defeat frame-based methods.
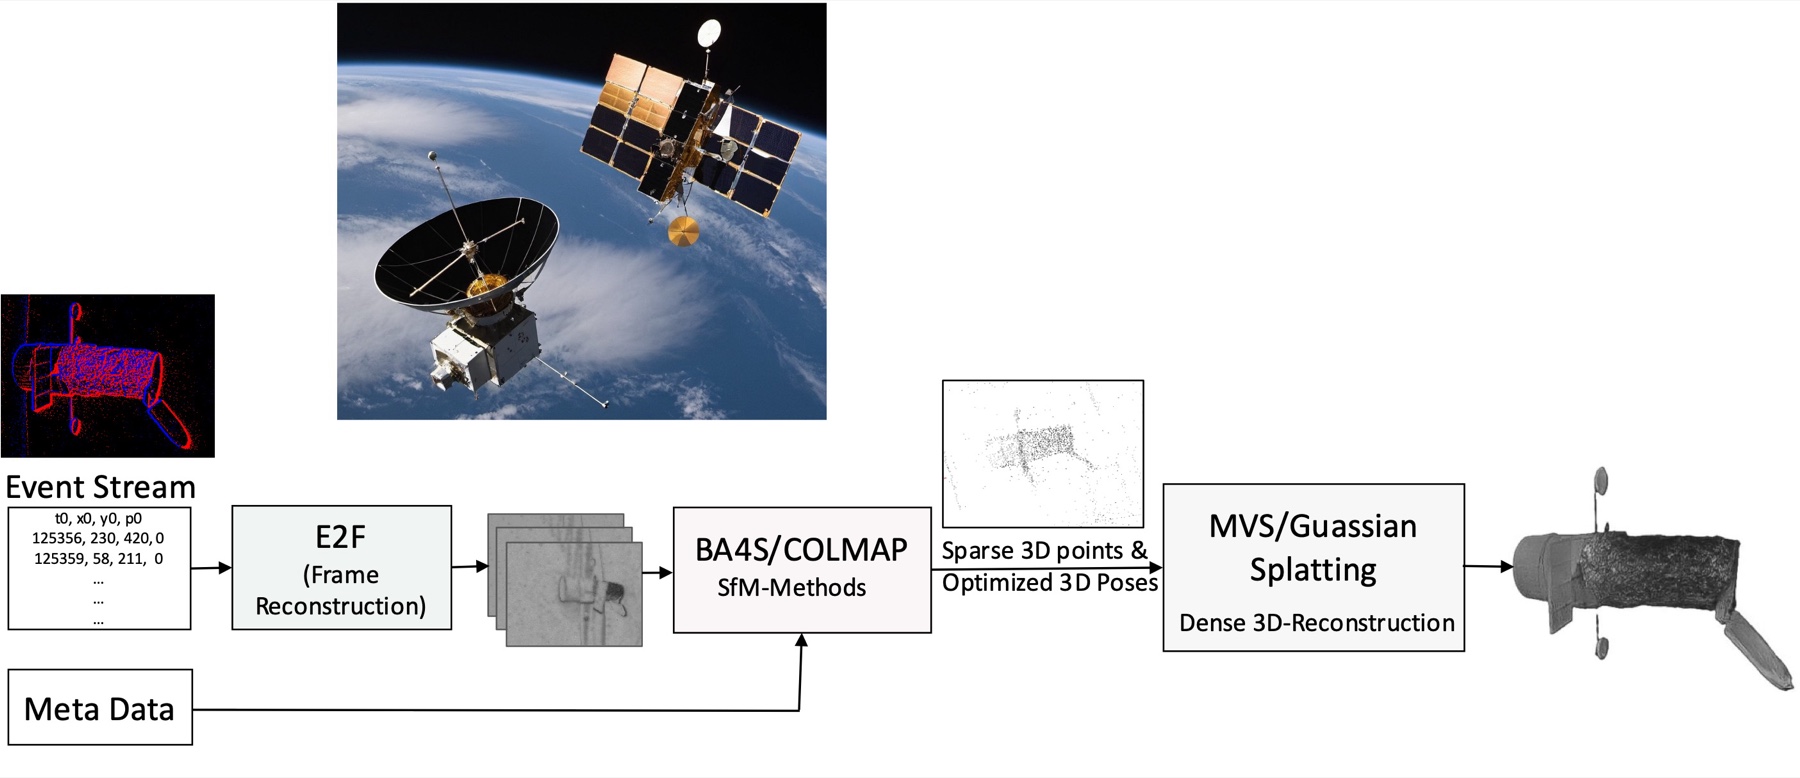
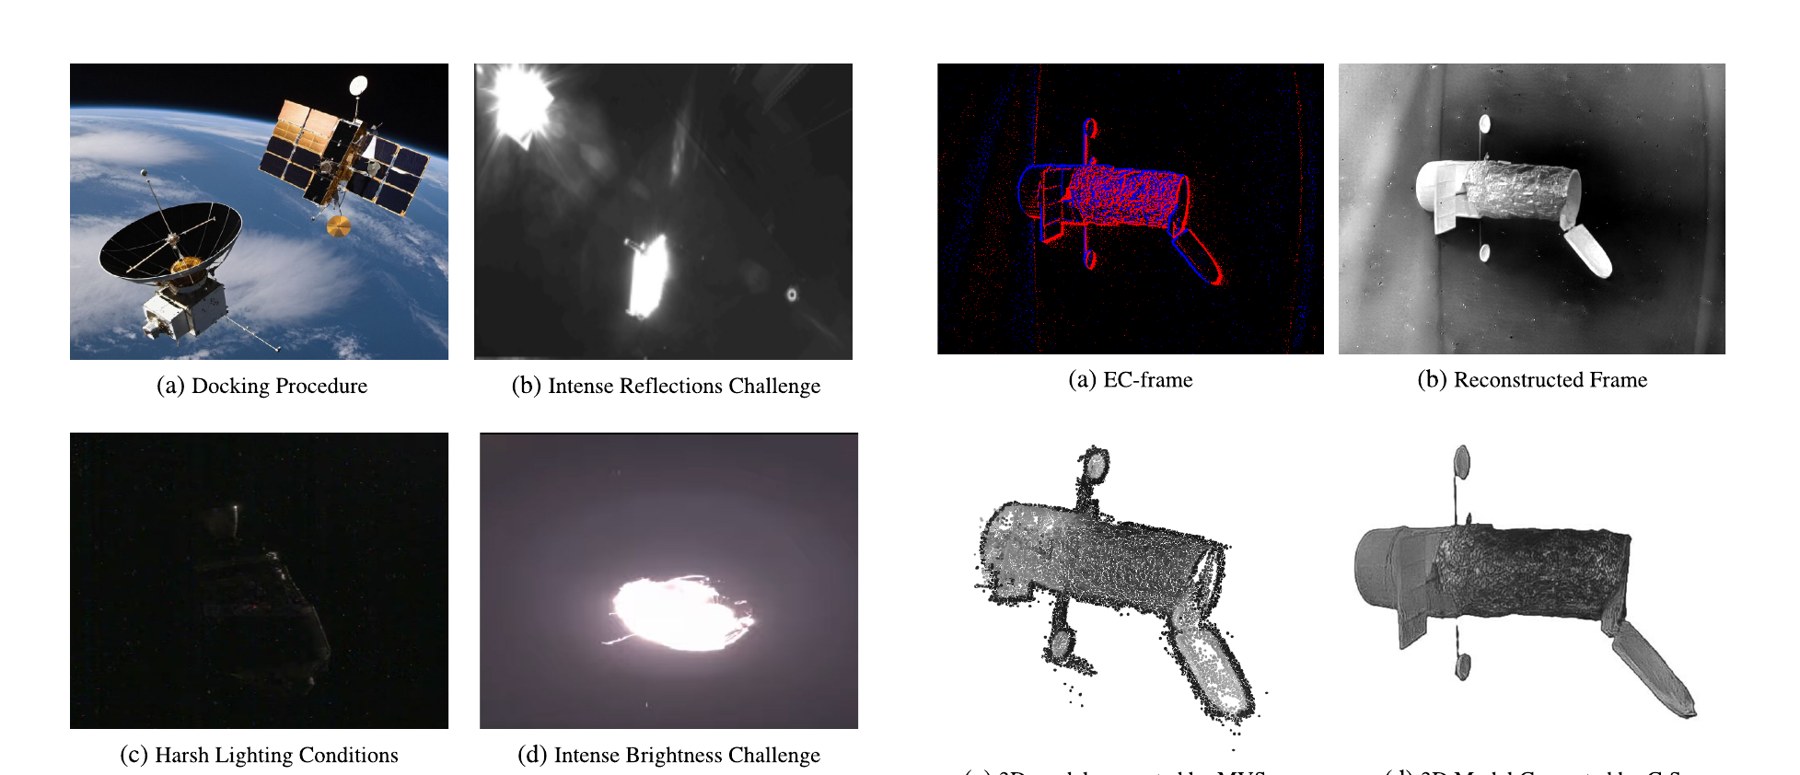
Satellites and other space objects present glare, saturation, and specular reflection that defeat frame-based structure-from-motion. EvSat3D uses the high dynamic range and fine temporal resolution of event cameras to estimate satellite pose and reconstruct 3D geometry under exactly these conditions, a step toward onboard, low-latency characterization of objects in orbit.
Publication
S. Malik, M. Moshrefizadeh, O. Tahri, X. Bai, E. Blasch, V. Sagan, and H. Ali Akbarpour. EvSat3D: Satellite Pose Estimation and 3D Reconstruction with Event Camera. IEEE Access, 2025. Paper